Construction Machinery High-temperature Crane and Trolley Positioning Model and Specification
High-temperature cranes in construction machinery plants, steel mills, and foundries require a reliable positioning model for the bridge, hoist, and trolley. The model uses a Cartesian coordinate frame referenced to the runway centerline, with absolute encoders, laser distance sensors, and redundant limit switches. It calculates trolley position from combined laser and encoder feedback, filters heat-induced signal drift, and outputs a real-time correction value to the PLC. The specification covers ambient temperature from -20°C to 120°C, positioning accuracy of ±5 mm, repeatability of ±2 mm, protection rating IP65, and communication via PROFINET or Modbus TCP. Heat shields, air cooling, and high-temperature cables protect sensors and drives. The system also defines calibration intervals, alarm thresholds, and maintenance checkpoints. For heavy-duty construction machinery, the model is integrated with anti-sway control and load monitoring. The specification defines mounting tolerances, cable routing, grounding, EMC requirements, and test procedures. During commissioning, engineers verify reference points at cold and hot states, record deviation curves, and set compensation tables. The control logic compares target and actual trolley coordinates, adjusts variable-frequency drives, and triggers safe stop if deviation exceeds 20 mm. This model improves safety, reduces misalignment during lifting, and supports stable operation under severe thermal conditions.
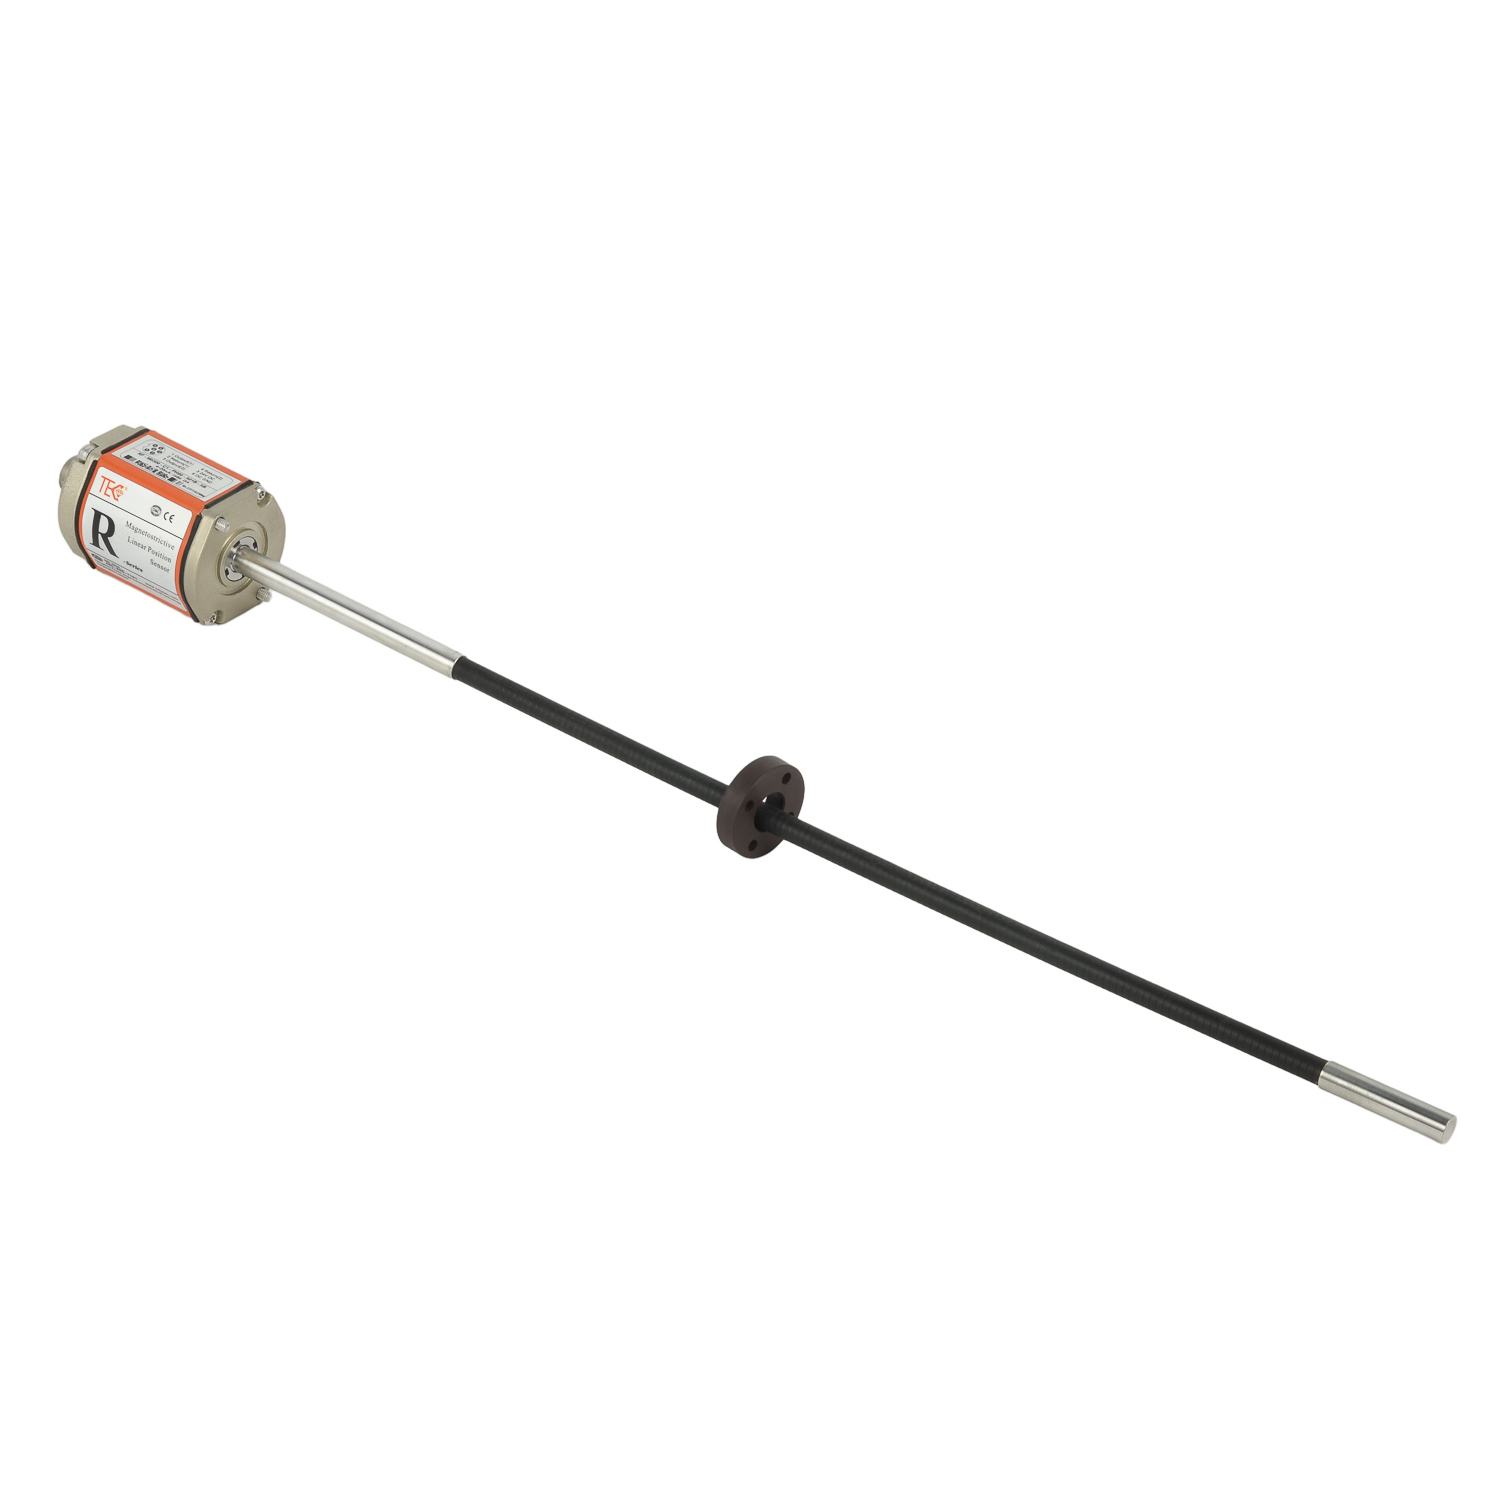
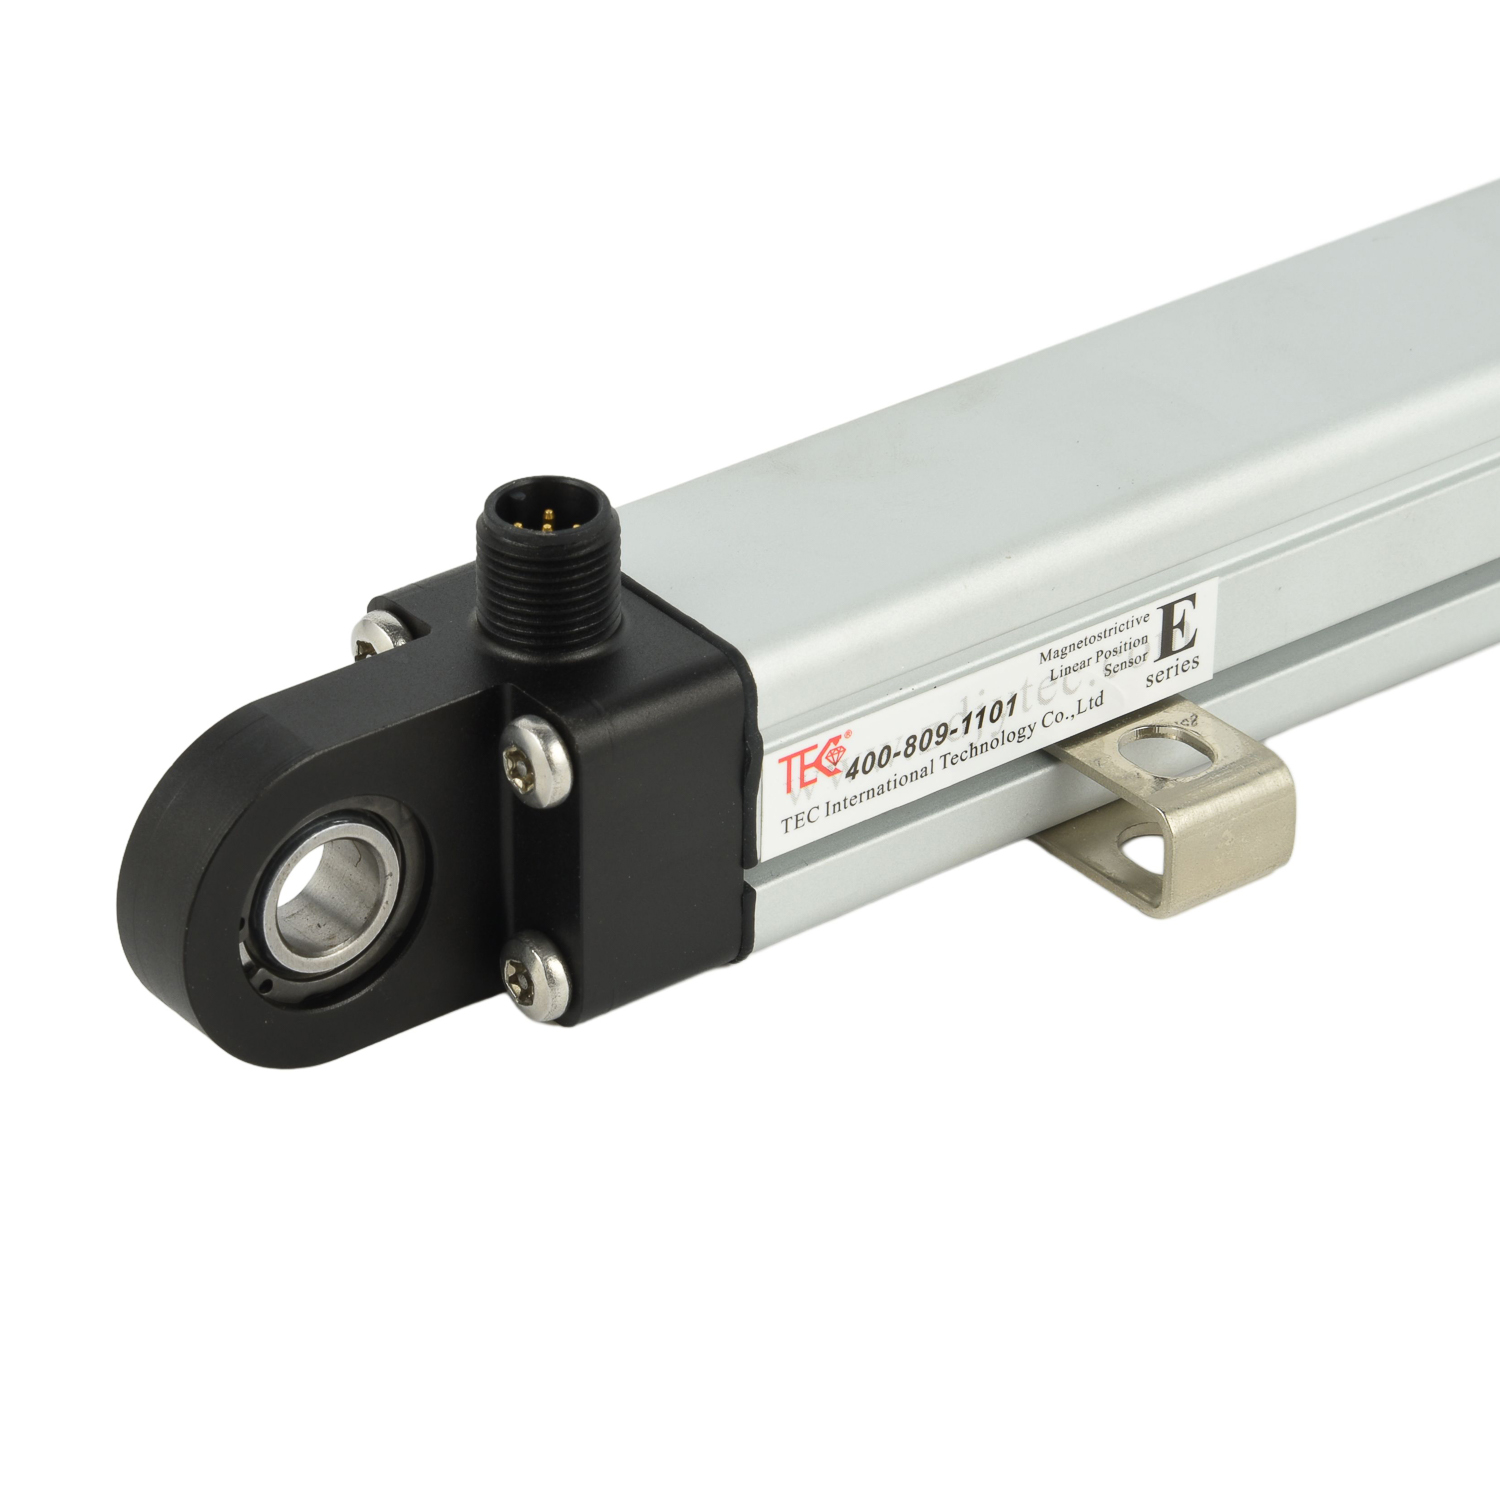 Overhead Crane High-pressure C
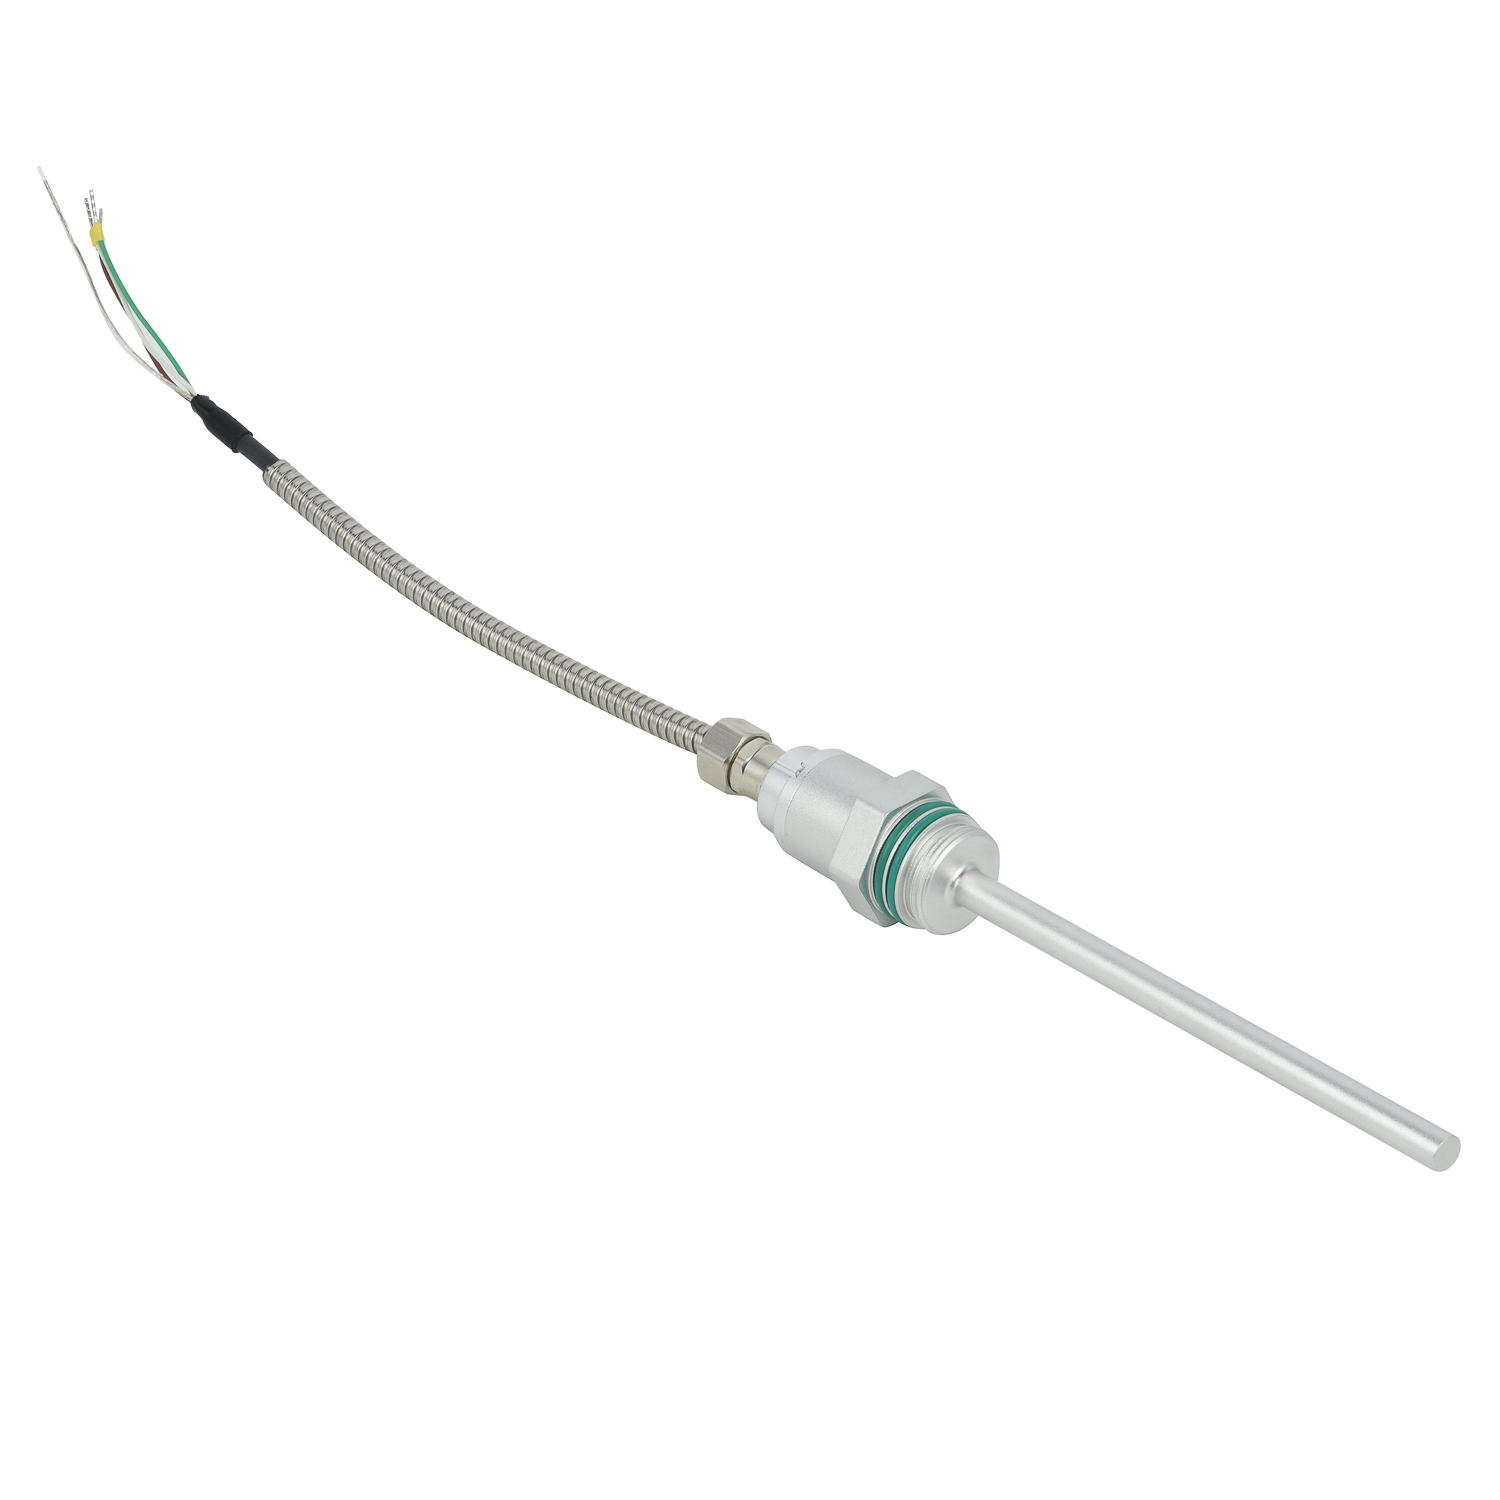 Stacker-reclaimer High-tempera
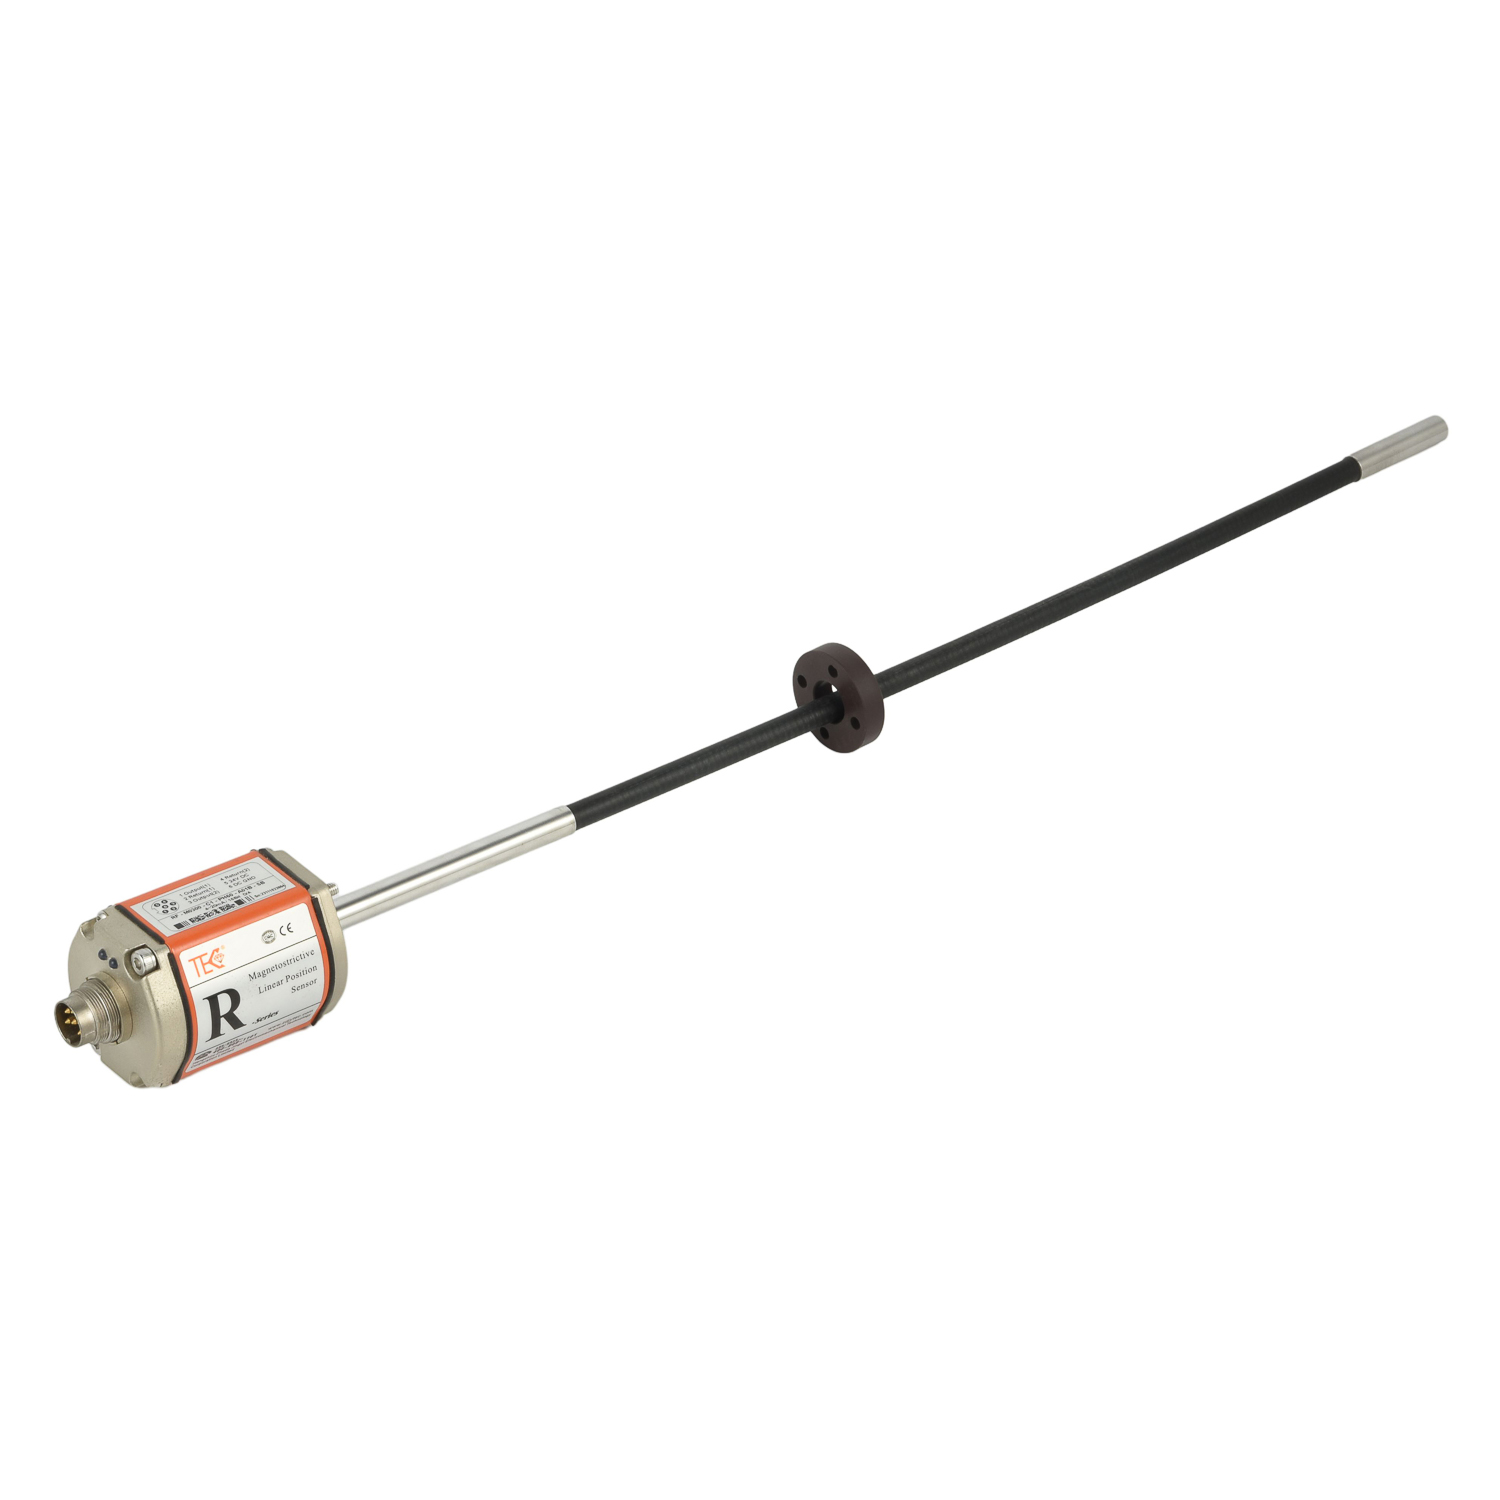 Bucket Wheel Stacker-reclaimer
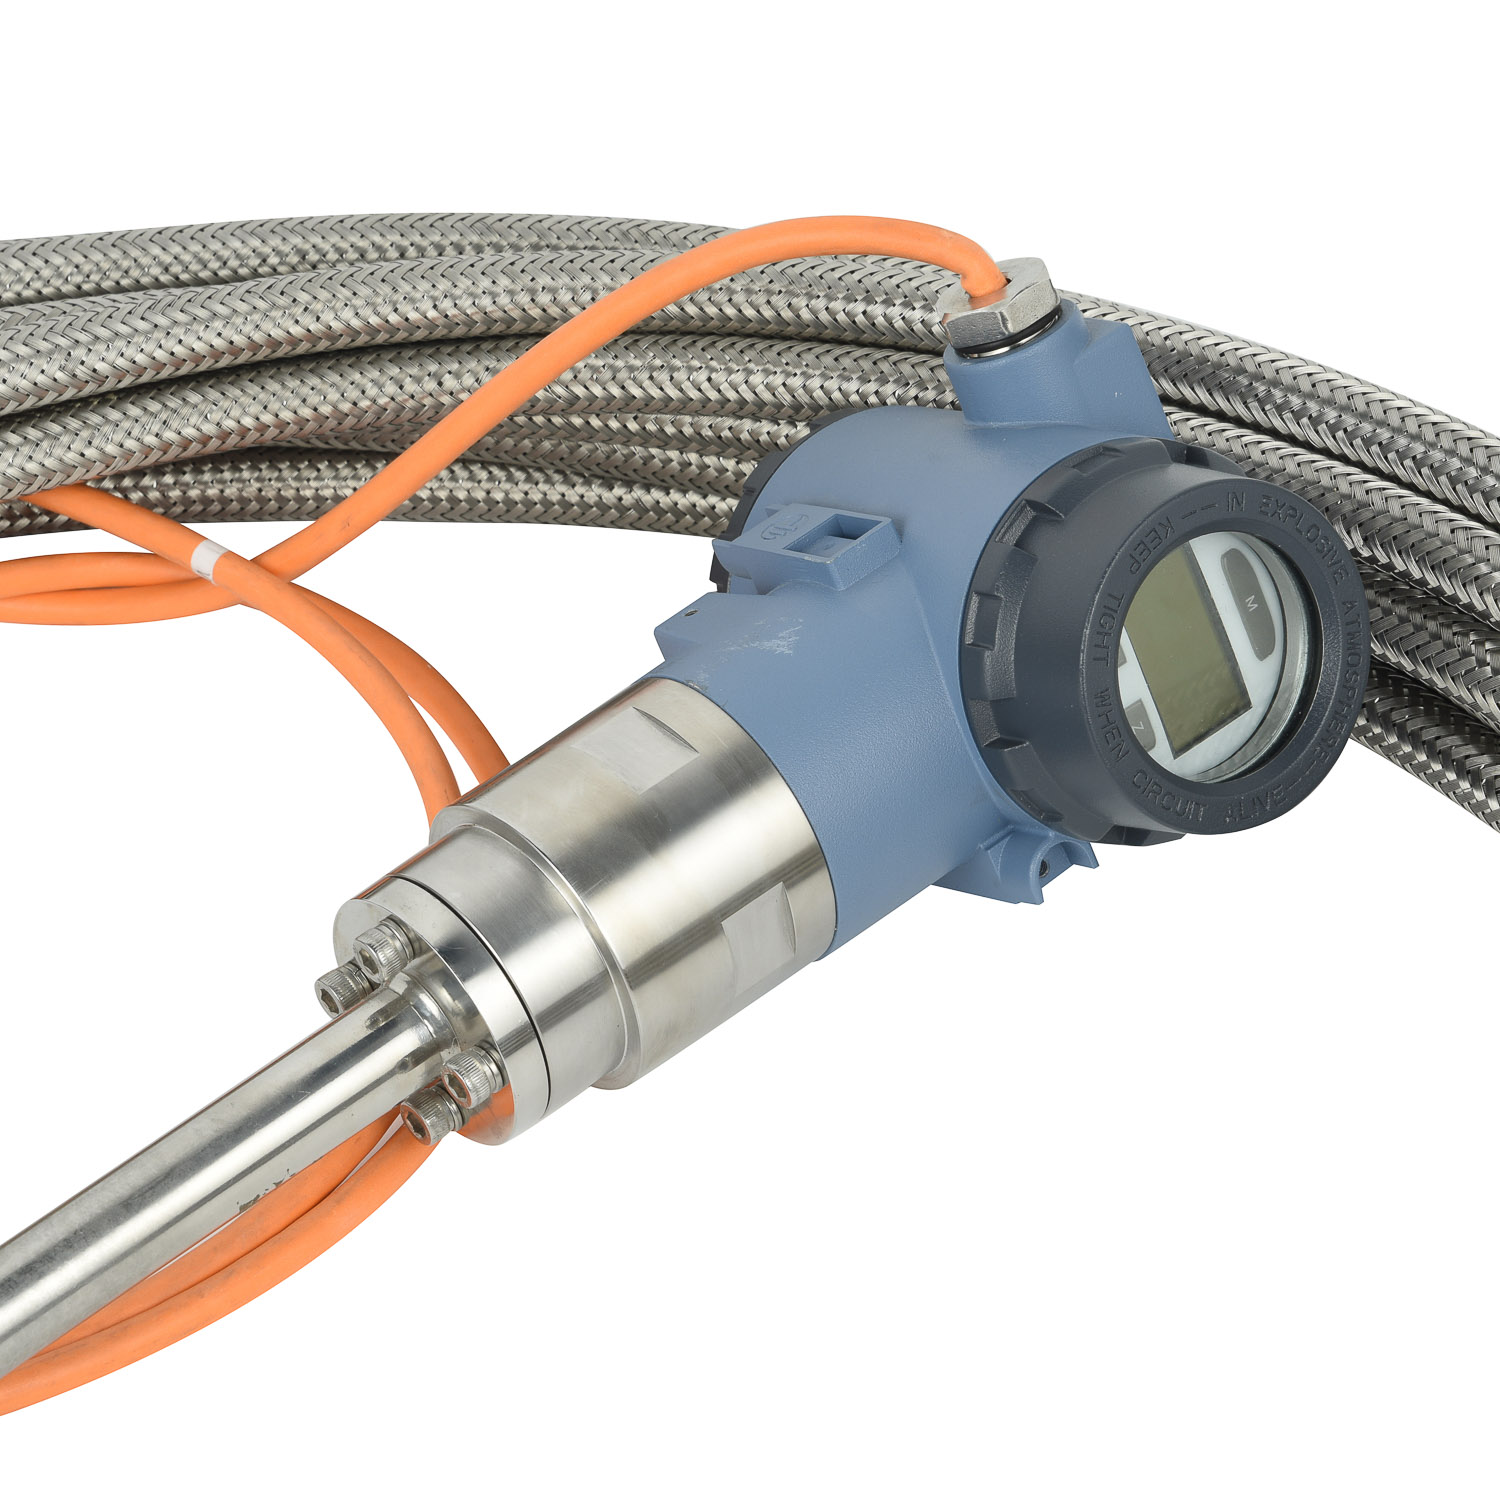 Mixing Station Explosion-proof