Metallurgy Overhead Crane Crane and Trolley Positioning Selection
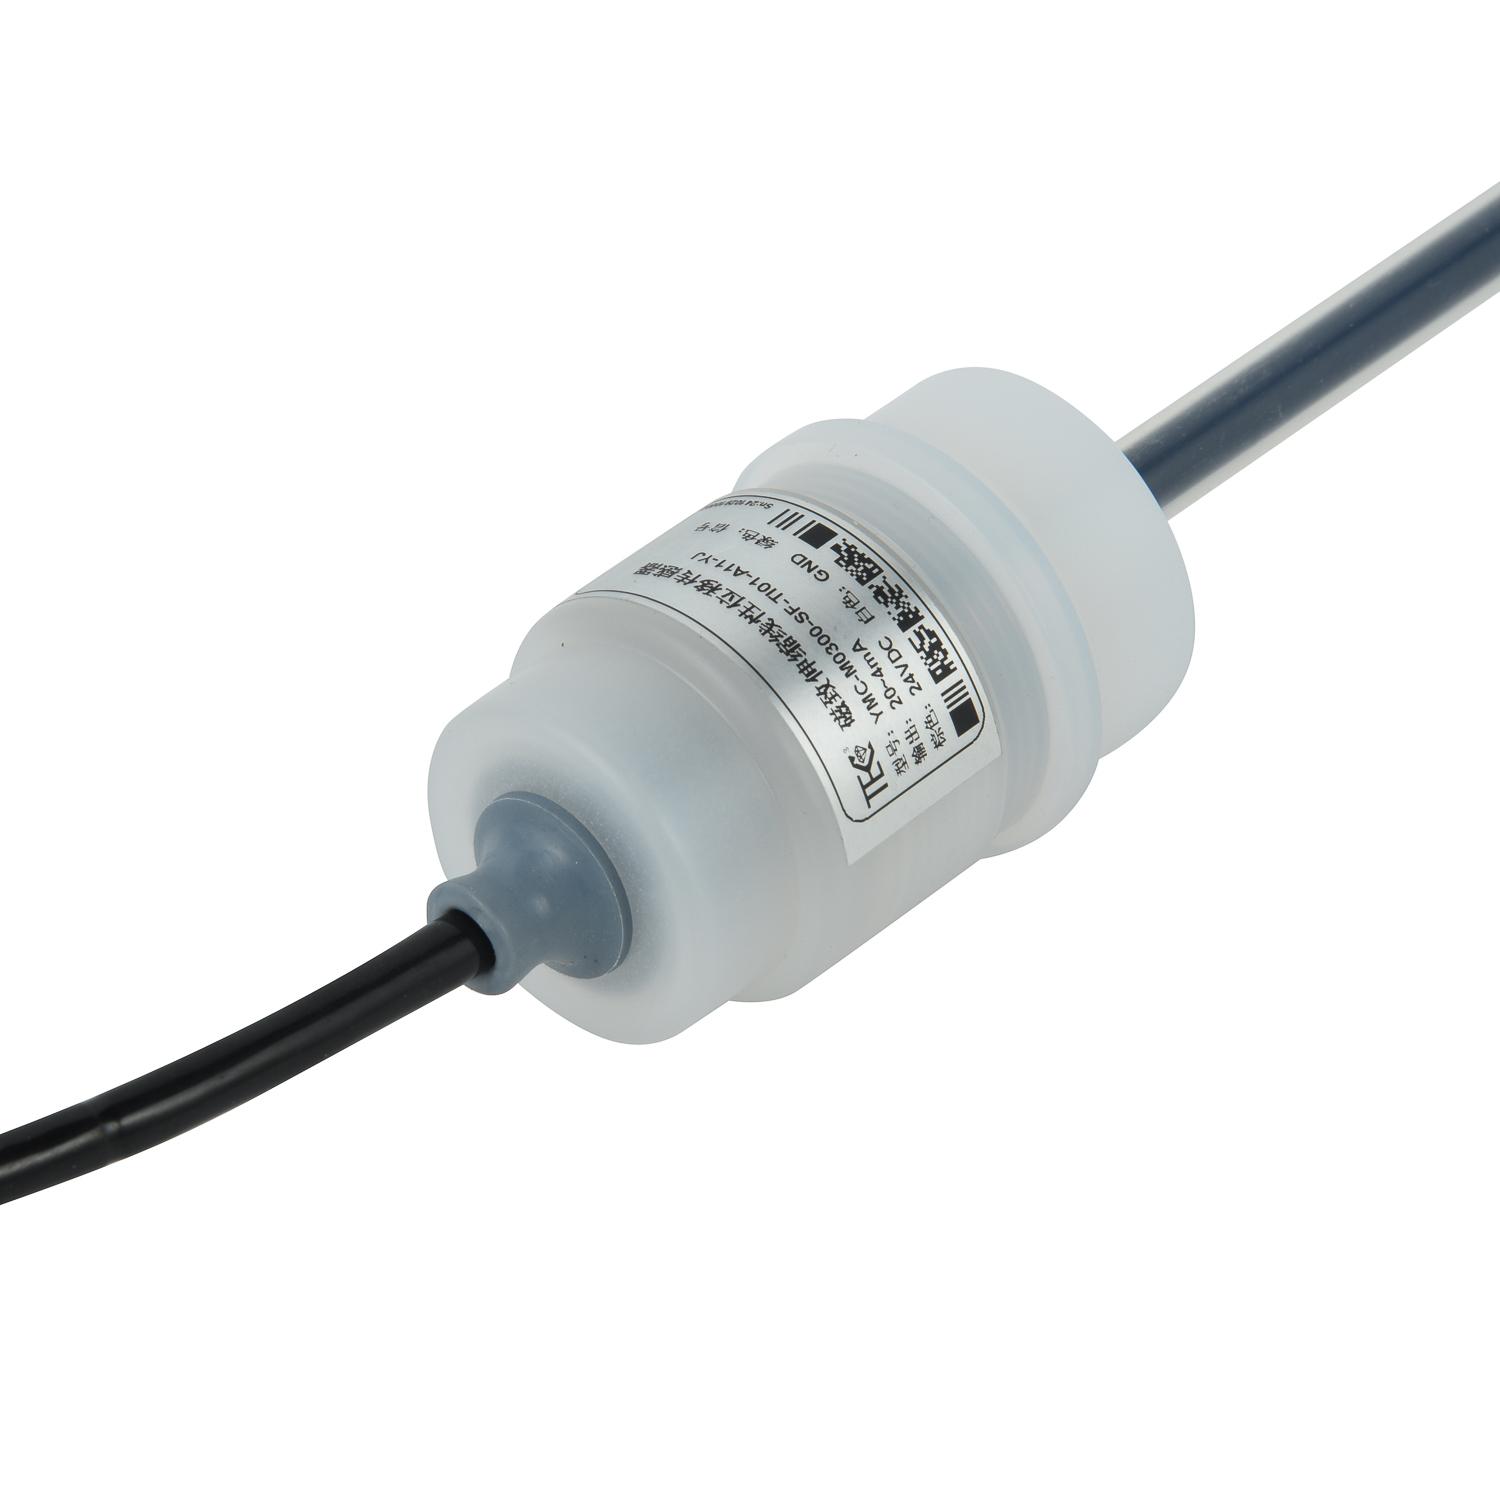
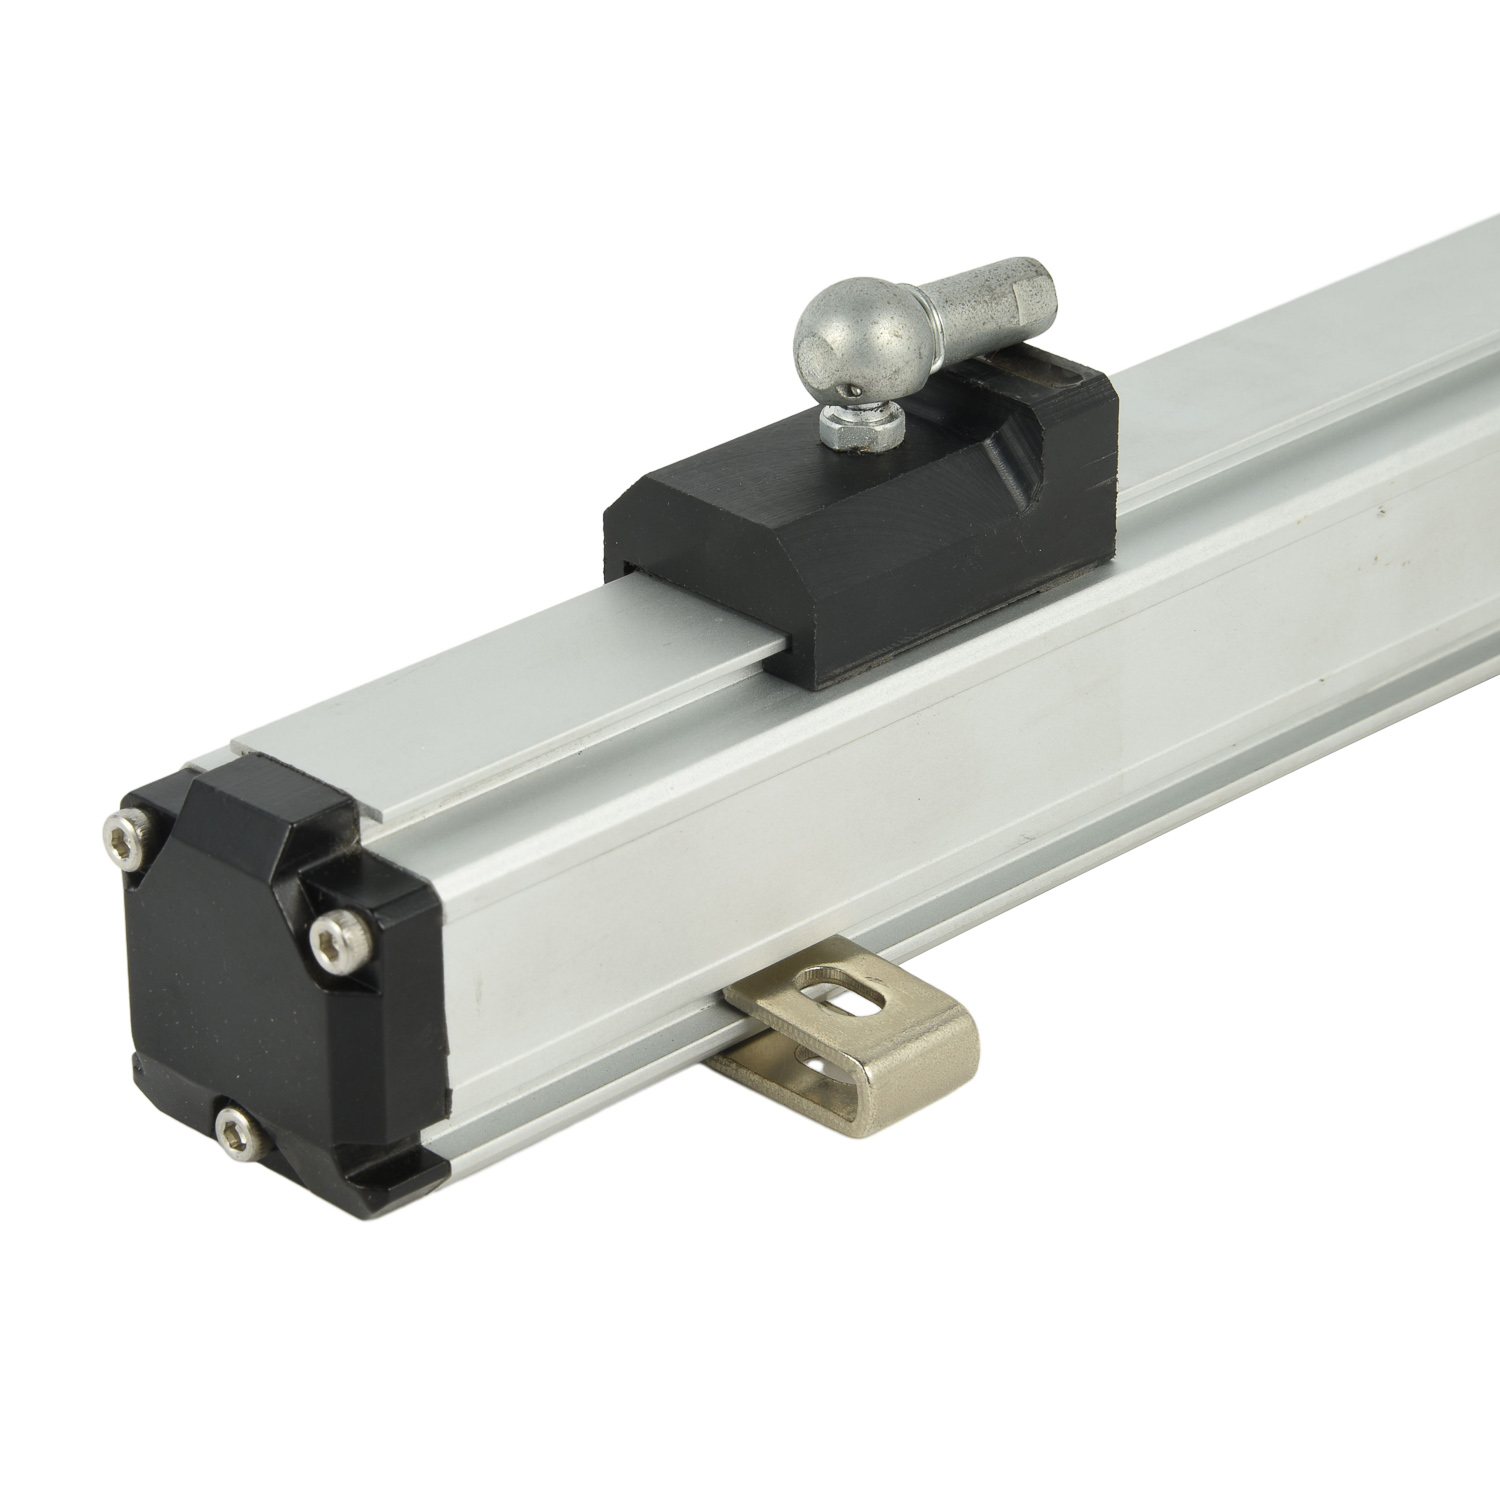
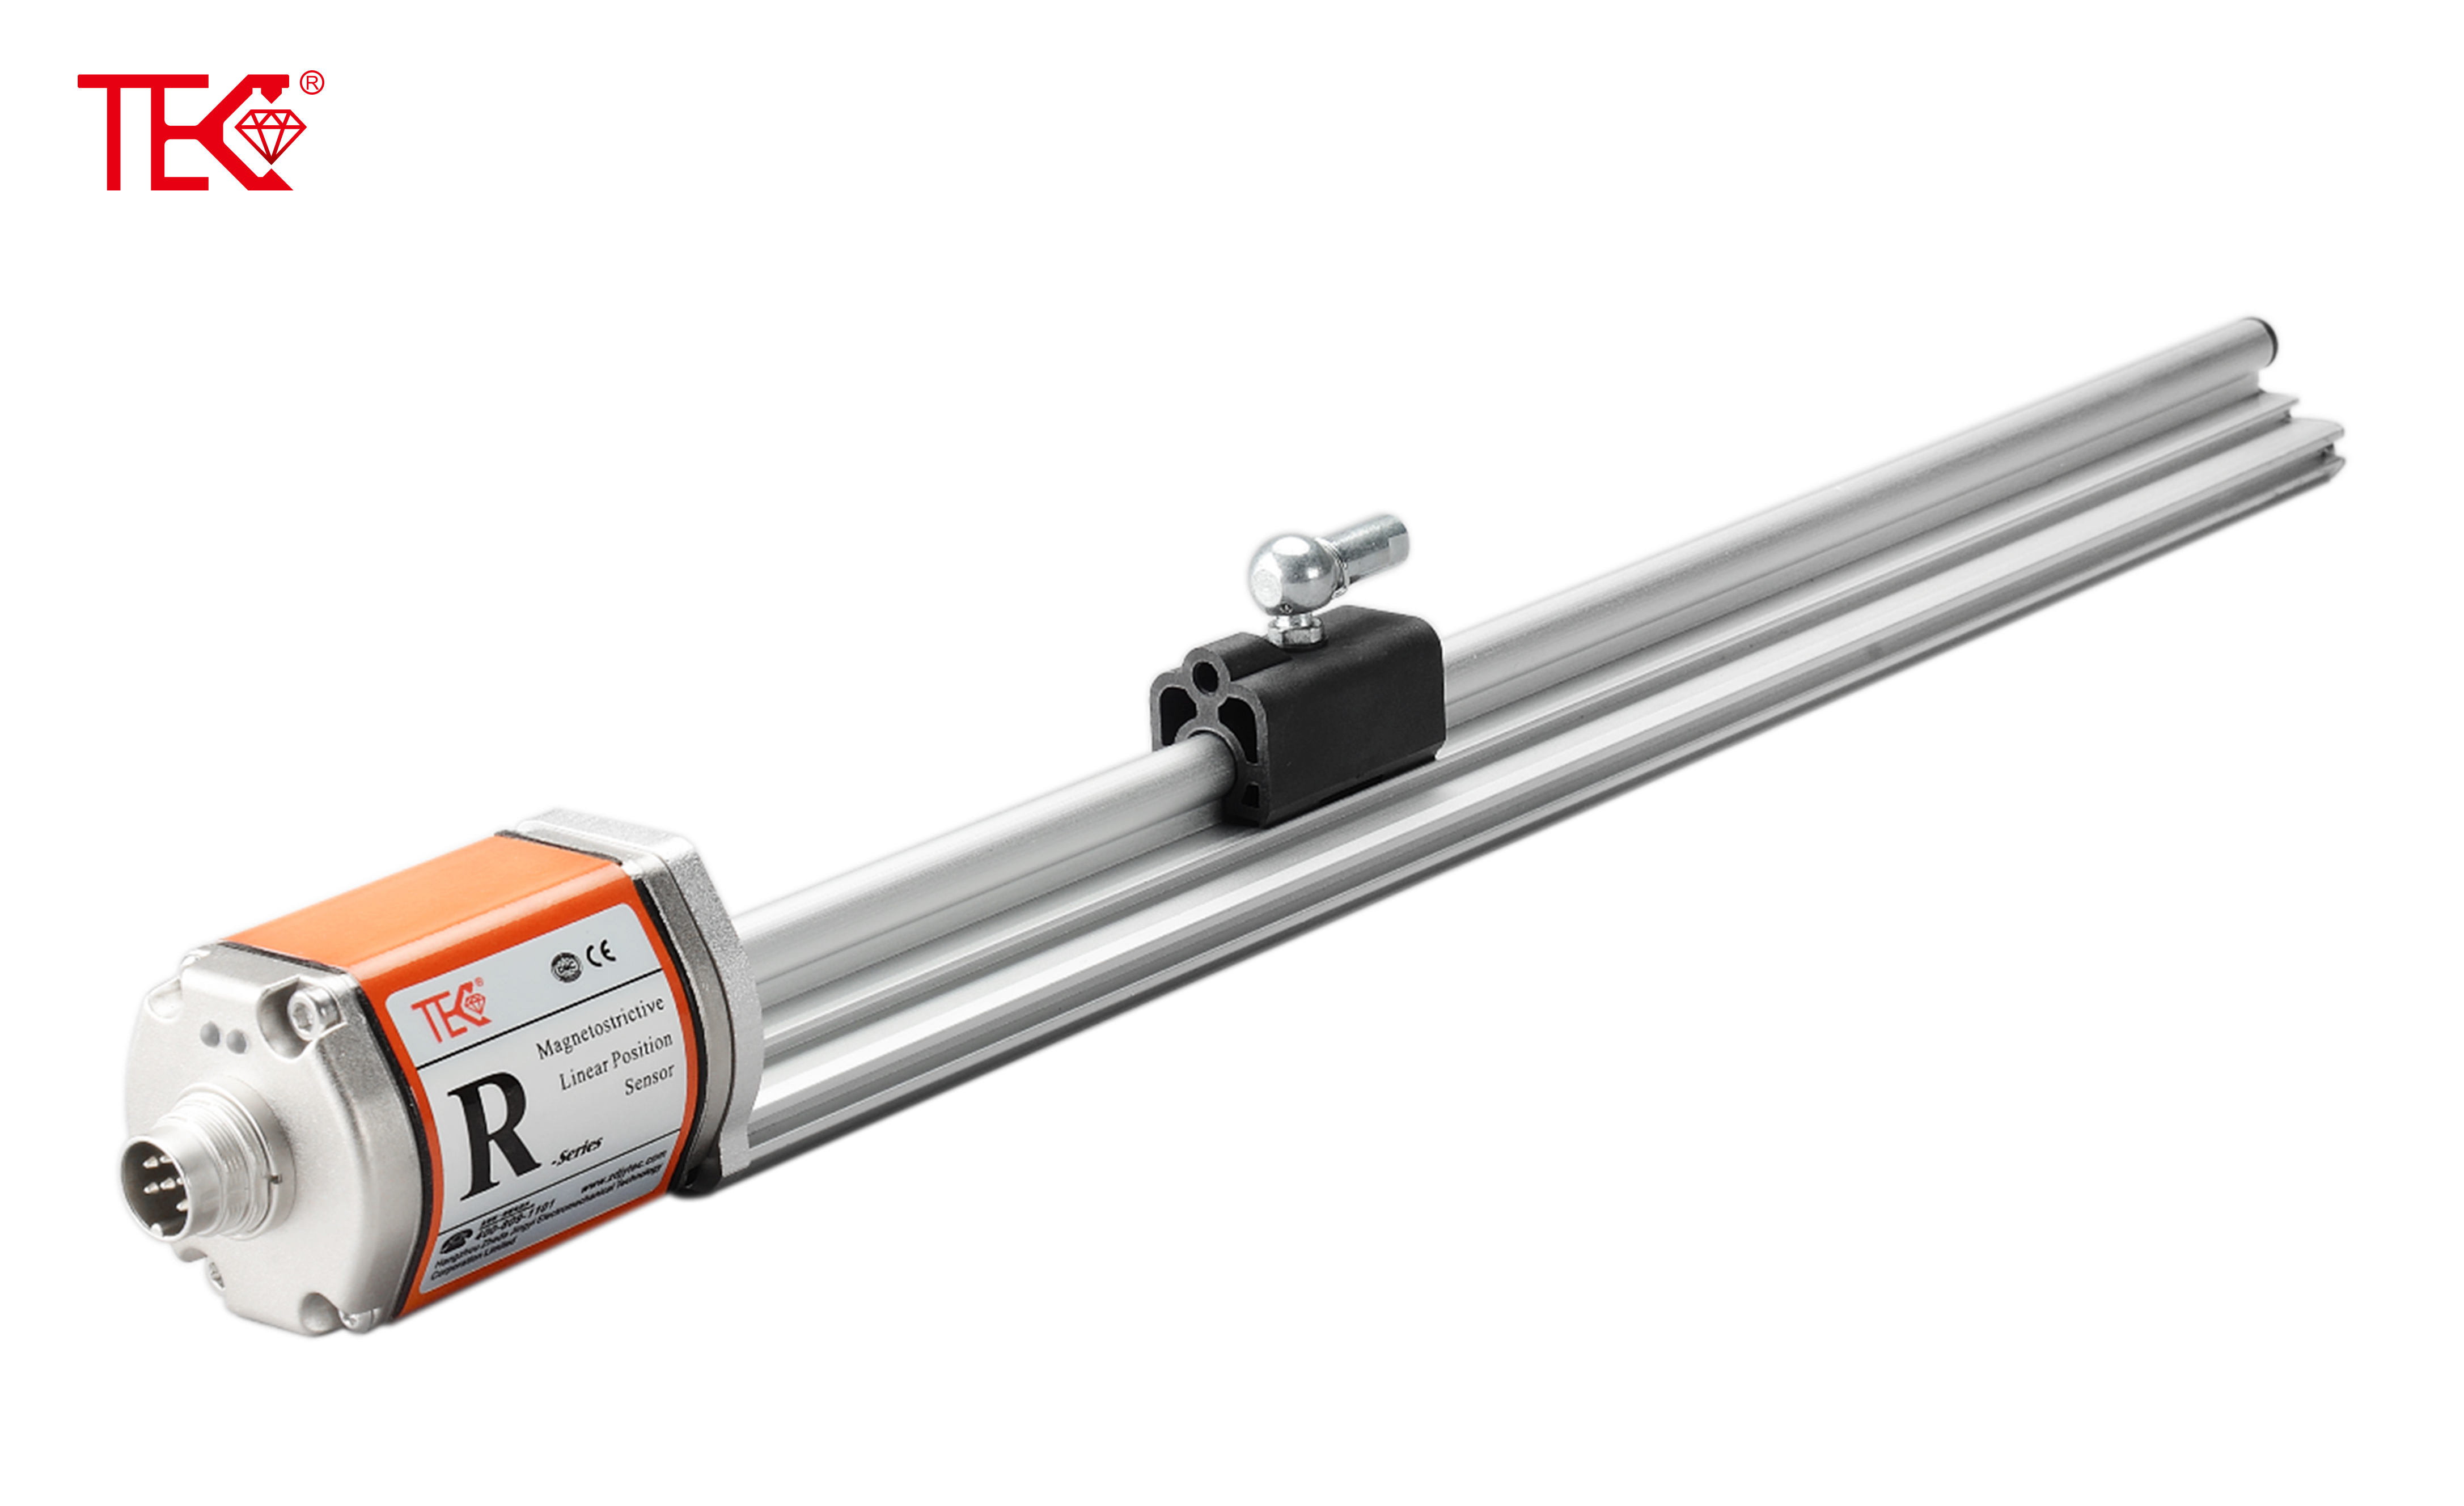
Selecting crane and trolley positioning for a metallurgy overhead crane requires a clear match between process accuracy, duty cycle, and the harsh steel-mill environment. First define the required stopping accuracy for the crane bridge and trolley, repeatability, travel speed, and whether positioning supports manual, semi-automatic, or fully automated operation. Ladle, charging, and slab-handling cranes often need tight repeatability at pick-up and drop-off points, while long travel axes may accept lower absolute accuracy if repeatable target stopping is stable. Sensor choice should follow the application. Absolute encoders on travel drives offer simple speed and distance feedback but can drift if wheel slip occurs. Laser distance measurement provides direct rail or reflector-based positioning and suits long travel with moderate dust; install shields and air purge in dirty areas. Magnetostrictive or magnetic scale systems deliver robust absolute feedback for trolley positioning where shock and vibration are high. RFID or code-tape systems are useful for zone and target identification, not continuous high-accuracy control. For critical ladle cranes, combine primary absolute measurement with encoder redundancy and mechanical limit protection. Integration matters. Confirm PLC compatibility, communication protocol, update rate, diagnostic output, and safety functions. Select IP-rated, heat-tolerant hardware with easy calibration and remote monitoring. A successful selection balances accuracy, reliability, maintenance access, and cost of ownership. Use actual travel lengths, target count, and duty cycle to validate the final system.
 Metallurgy Overhead Crane Cran
 Grain and Oil Storage Tank Hig
 Mixing Station Silo Explosion-
 Shield Tunneling High-temperat