Construction Machinery Bridge Crane Crane and Trolley Positioning Model and Specification
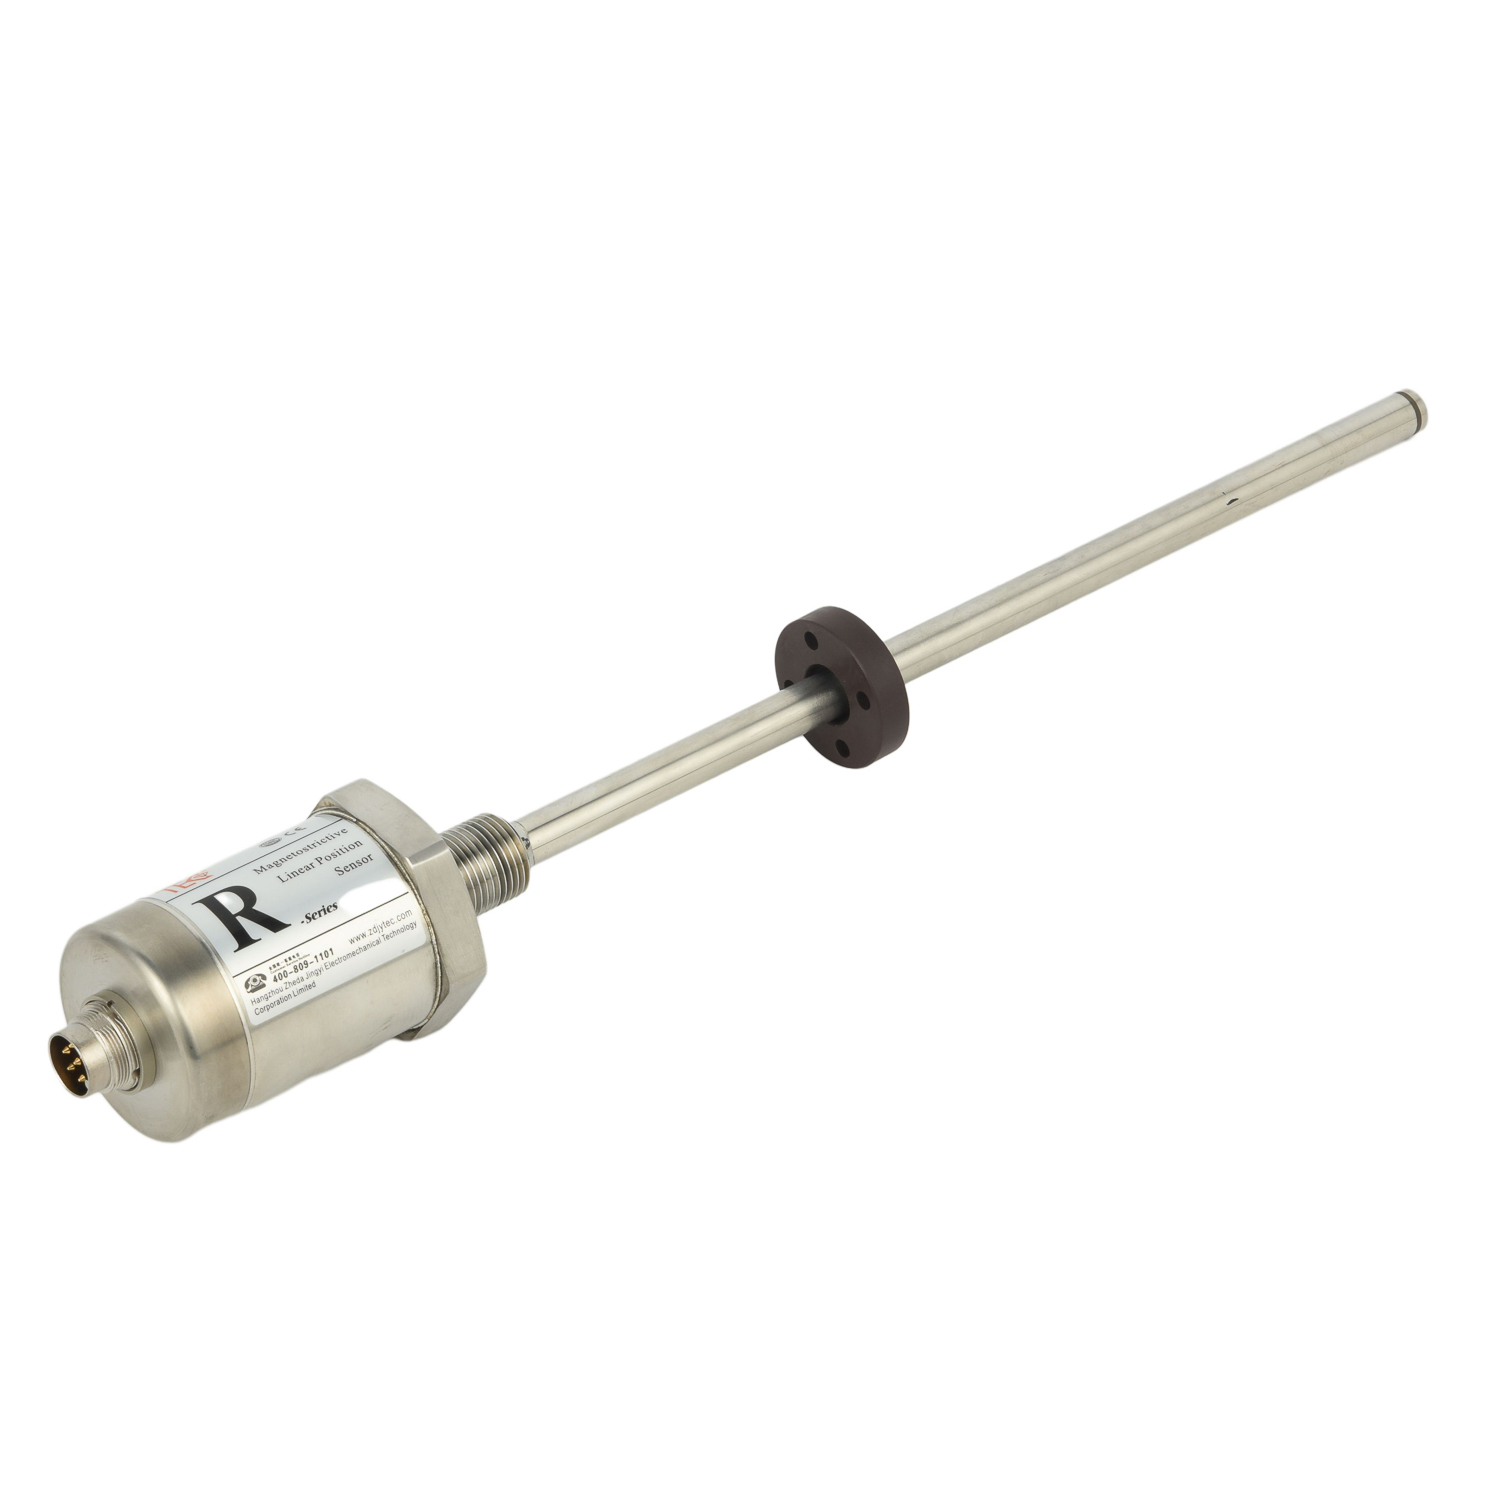
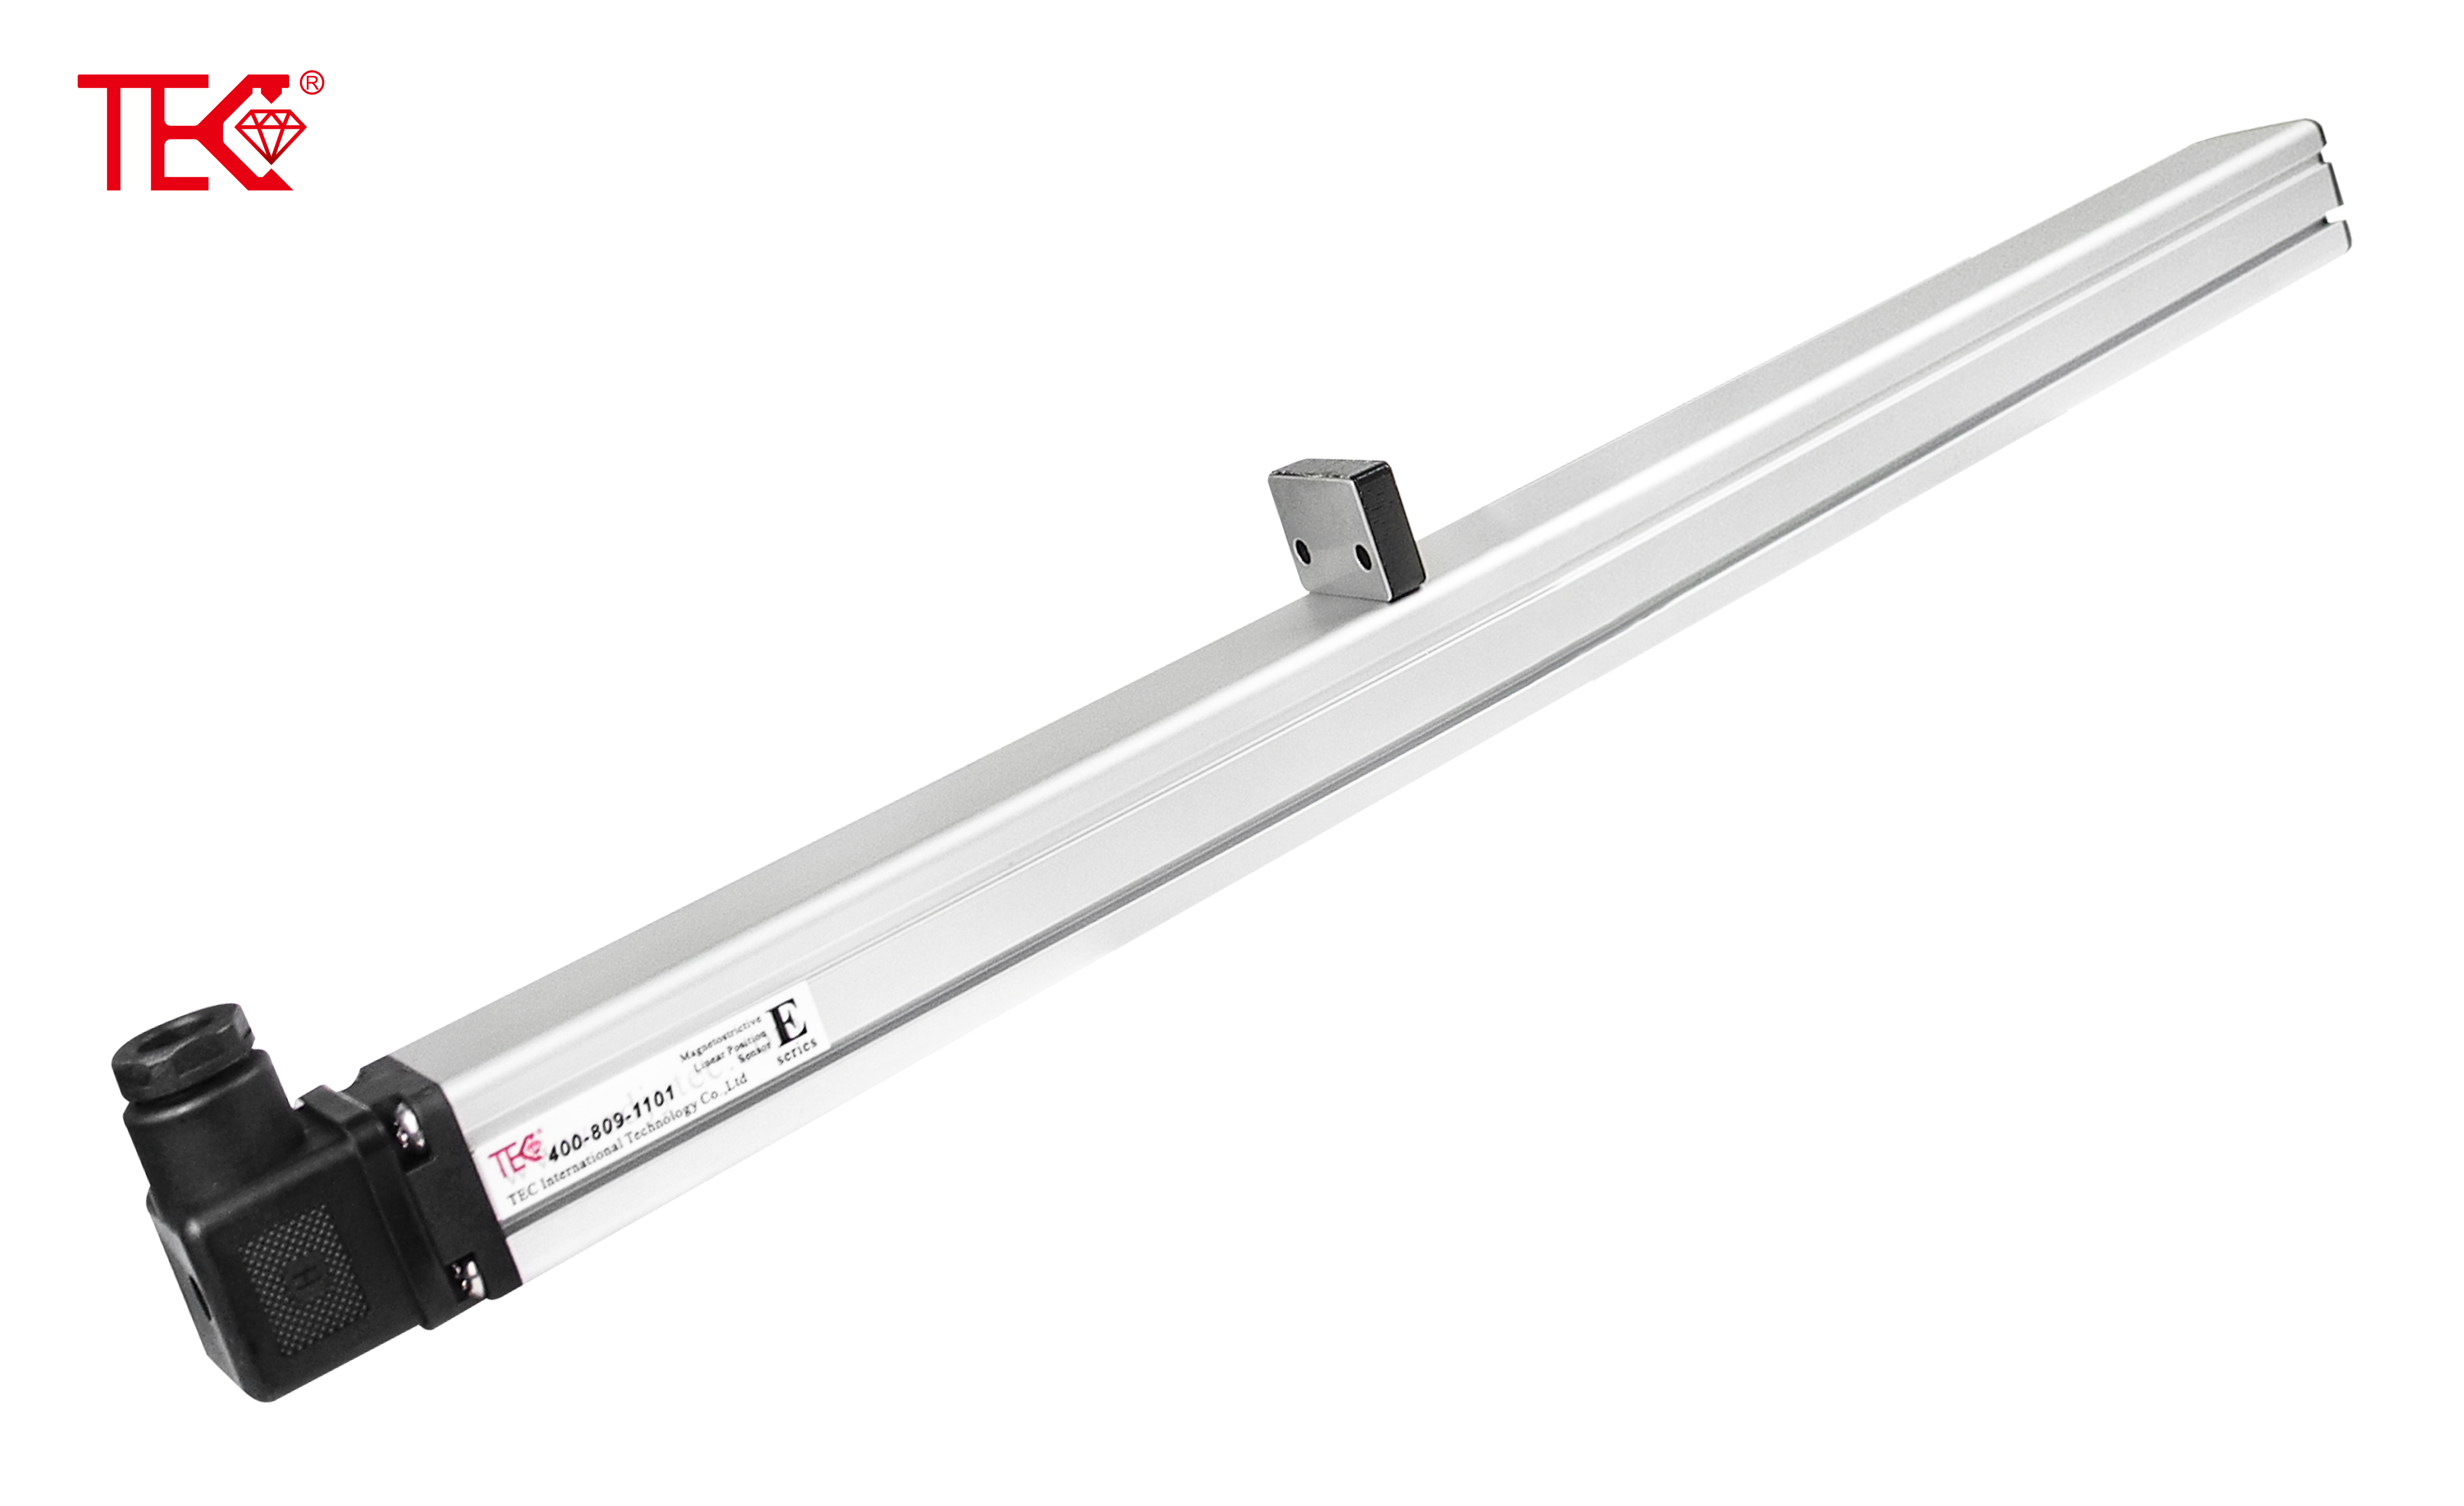
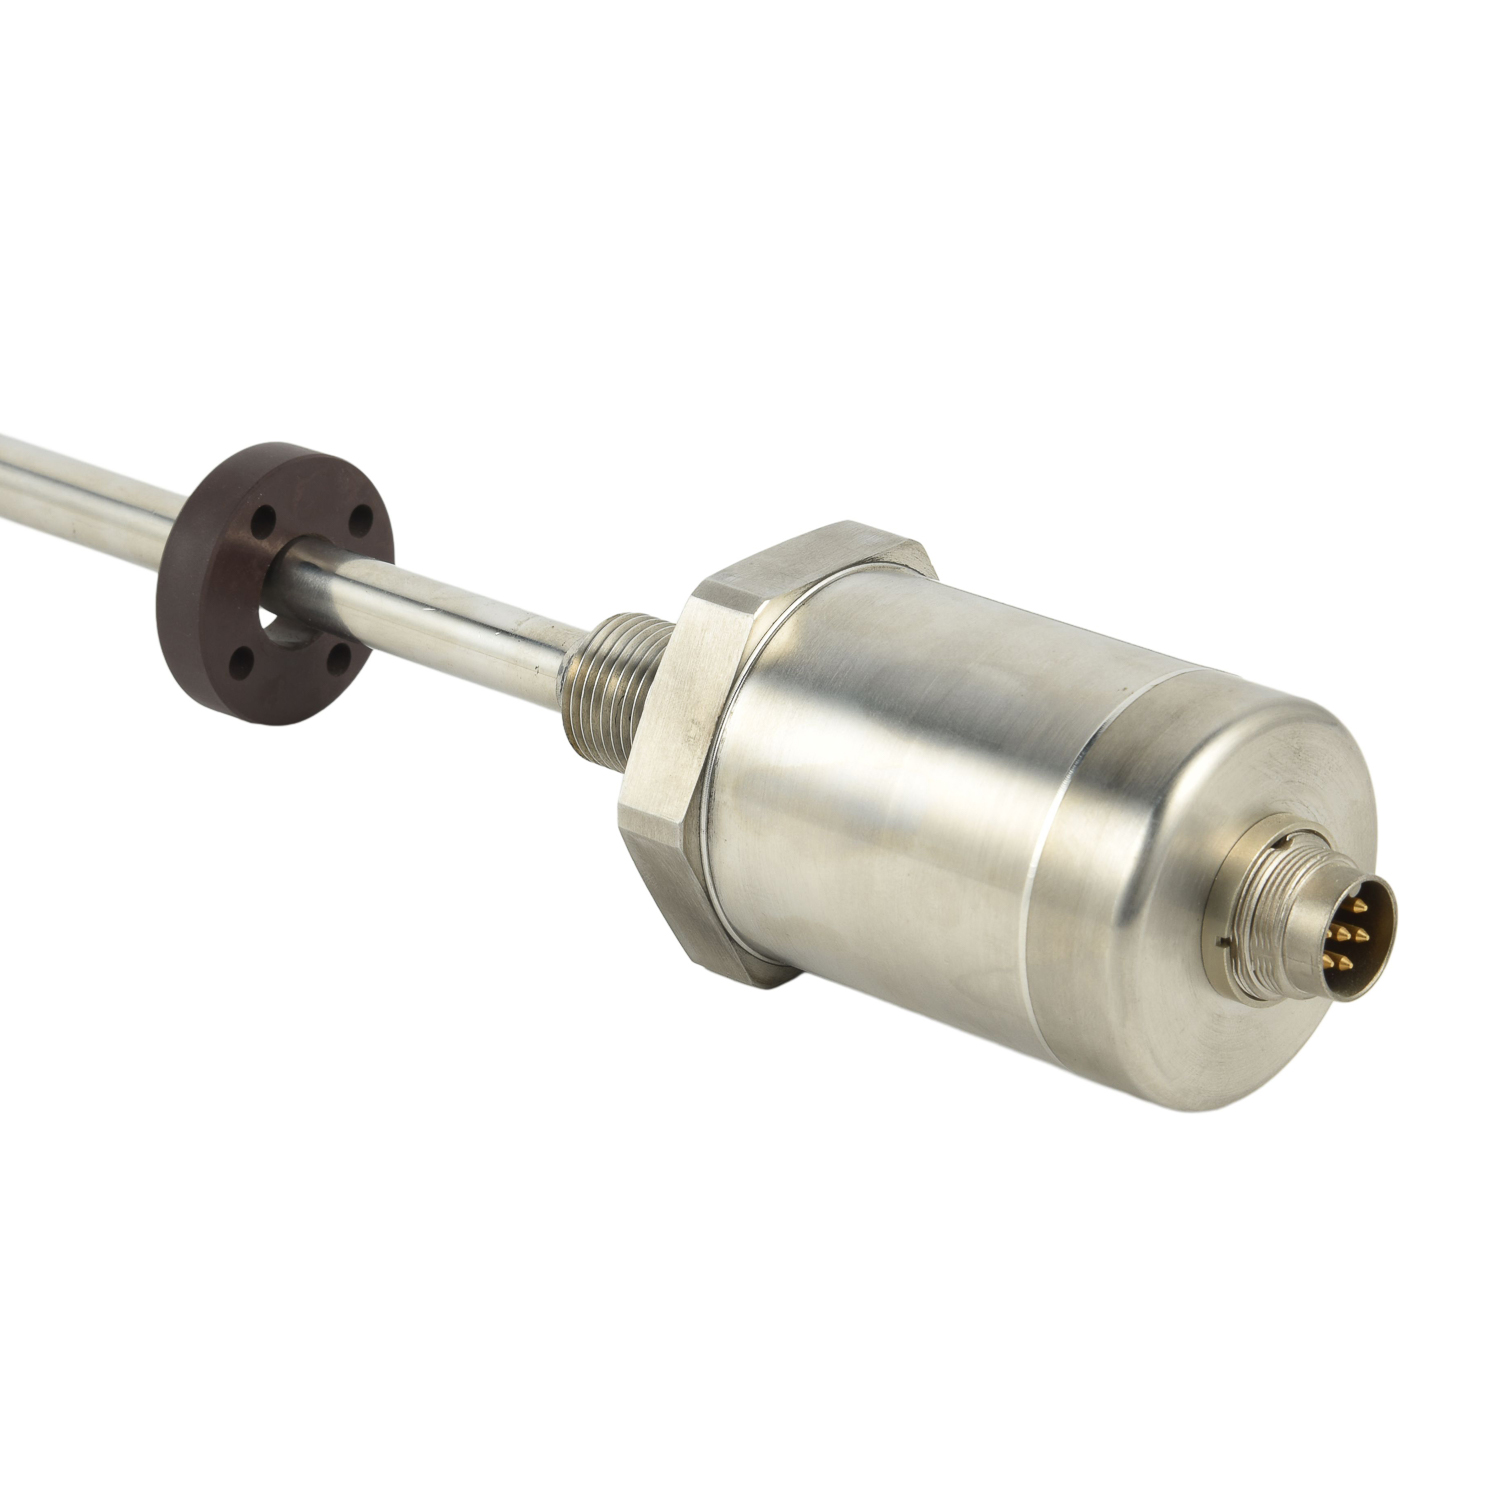
Bridge cranes in construction machinery need reliable crane and trolley positioning to deliver safe lifts, repeatable placement, and efficient material handling. A useful positioning model starts with clear coordinates: crane runway axis, trolley travel axis, hoist height, and load reference point. The model links encoder counts, absolute sensors, laser rangefinders, and vision data through a PLC or motion controller. It then calculates target coordinates, applies anti-sway control, and compensates for wheel slip, rail deviation, and structural flex. Specification selection should define span, lifting capacity, trolley speed, crane travel speed, hoist speed, positioning accuracy, repeatability, duty class, voltage, control interface, and safety functions. For construction sites, specify IP ratings, brake logic, limit switches, emergency stop response, and communication protocol. During commissioning, test empty and loaded moves at low and high speed. Record overshoot, settling time, and repeatability at each workstation. Calibrate the model against measured rail positions and load points, then verify limits and interlocks. Use trend data to adjust gain values and sensor fusion weights as rails settle or loads change. Document the final model with coordinate drawings, sensor maps, parameter tables, and acceptance test records so maintenance teams can repeat calibration and troubleshoot positioning faults. A well-defined positioning model and specification improve lifting productivity, reduce swing risk, and support automation-ready bridge crane operation.
 Injection Molding Die Casting
Construction Machinery Bridge
 Power Plant Crane Explosion-pr
 Port Overhead Crane Intrinsica